Dhruv Patel

Dhruv Patel

About me

NOTE: Website content is not updated frequently. Please check LinkedIn for the most recent updates.

I am a Robotics Researcher at Samsung Research America, working on robot learning and multimodal foundation models for contact-rich manipulation. My current research focuses on World Action Models (WAMs), dexterous manipulation, and multimodal learning for physical interaction, with the broader goal of building general-purpose robot intelligence for home and manufacturing applications.

I completed my M.S. in Robotics at Georgia Tech, where I worked with Dr. Danfei Xu in the Robot Learning and Reasoning (RL2) Lab on robot learning from embodied human data. My research spanned bimanual and mobile manipulation, Vision-Language-Action models, and embodiment-agnostic representation learning, with projects including EgoMimic, EgoBridge, and EgoMimic-Mobile. I also contributed to EgoVerse, a broader multi-institution effort on embodied human data for robot learning involving researchers from UC San Diego, Stanford, ETH Zurich, Meta AI, and other collaborators.

Across academia and industry, I have worked on robot learning, computer vision, autonomous systems, SLAM, and embodied AI. I have worked at Path Robotics on an initial robot learning POC for manufacturing manipulation; at Honda Research Institute USA on perception and scene understanding for autonomous vehicles at intersections; and as a Google Summer of Code contributor on differentiable SLAM and multi-framework support for GradSLAM.

Prior to Georgia Tech, I was a Research Associate at the Robotics Research Center, IIIT Hyderabad, focusing on adverse-weather perception for autonomous driving in collaboration with Queensland University of Technology (QUT) and ZF Friedrichshafen, while also leading research on UAV-based visual remote sensing for automated building inspection and civil infrastructure assessment. Earlier, I contributed to SLAM and LiDAR mapping for autonomous driving at Swaayatt Robots and held a Software Engineering role at Amdocs.

My broader research interests lie in robot foundation models, multimodal robot learning, dexterous and contact-rich manipulation and learning from human data.

I am always open to research collaborations, technical discussions, and interesting conversations around AI and Robotics. Feel free to connect with me on LinkedIn or reach out via email.

Interests

  • Robotics & Computer Vision
  • Deep Learning
  • AI & Neuroscience

Education

  • MS in Robotics, August 2023- May 2025

    Georgia Institute of Technology (Georgia Tech)

  • B.Tech in Electronics & Communication Engg, July 2016 - July 2020

    Sardar Vallabhbhai National Institute of Technology, Surat

Recent

Work Experience


Georgia Tech Logo

Graduate Student Researcher

Robot Learning and Reasoning Lab (RL2), Georgia Tech

Nov 2023 - Present
Advisor: Dr. Danfei Xu
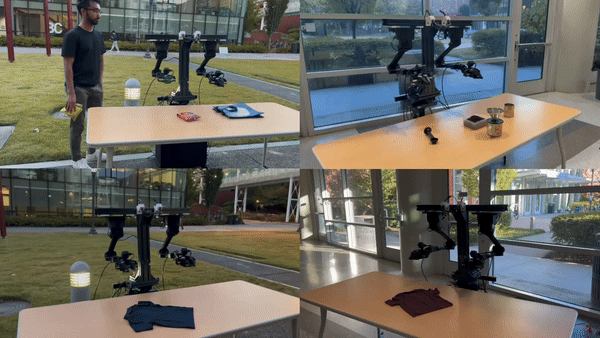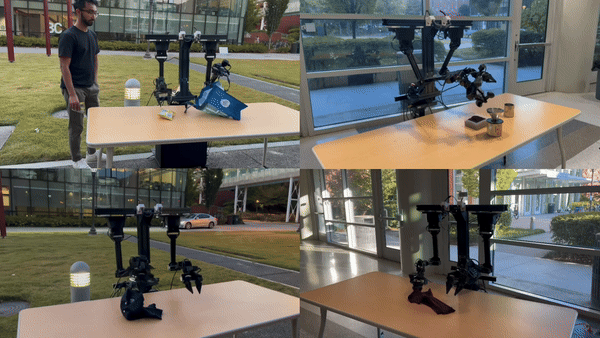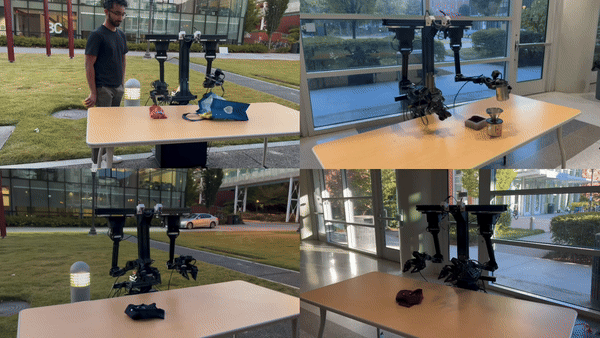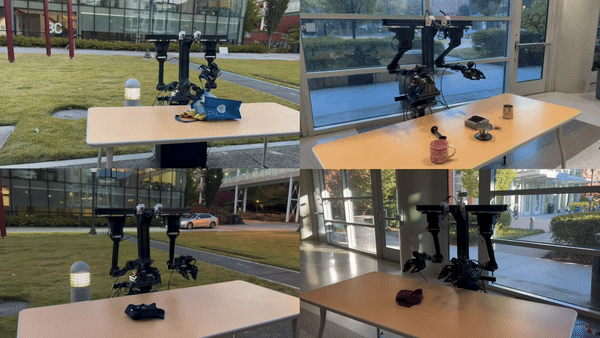
Cross-Embodiment Learning for Robot Manipulation using Embodied Human-Play Data [WebPage]
Keywords: Robot Learning, Manipulation, Imitation Learning


Honda Research Institute Logo

Research Associate Intern

Honda Research Institute, USA

May 2024 - August 2024
Developed perception algorithms for intersection detection and navigation for HRI’s Autonomous Vehicle (AV) platform.
Keywords: Scene Understanding, ADAS, Robotics, Deep Learning


Google Summer of Code Logo

Open-Source Software Developer

Google Summer of Code 2023

June 2023 - August 2023
Multi-backend framework support of GradSLAM in Ivy [WebSite]

  • Google Summer of Code '23 Contributor at Ivy - unify.ai
  • Developed a multi-backend framework support (PyTorch, JAX, NumPy, Tensorflow) for GradSLAM library in Ivy, with an aim to optimize deployment through highly efficient frameworks like JAX.
Keywords: Robotics, Deep Learning, PyTorch, JAX, NumPy, Tensorflow


Robotics Research Centre Logo

Project Associate

Robotics Research Centre (RRC), IIIT Hyderabad

July 2021 – July 2023
Scene Understanding for Autonomous Driving
Advisors: Prof. Madhava Krishna and Dr. Sourav Garg

  • Collaborated with ZF Friedrichshafen group and Queensland University of Technology (QUT) Robotics on improving perception and scene understanding for adverse weather conditions.
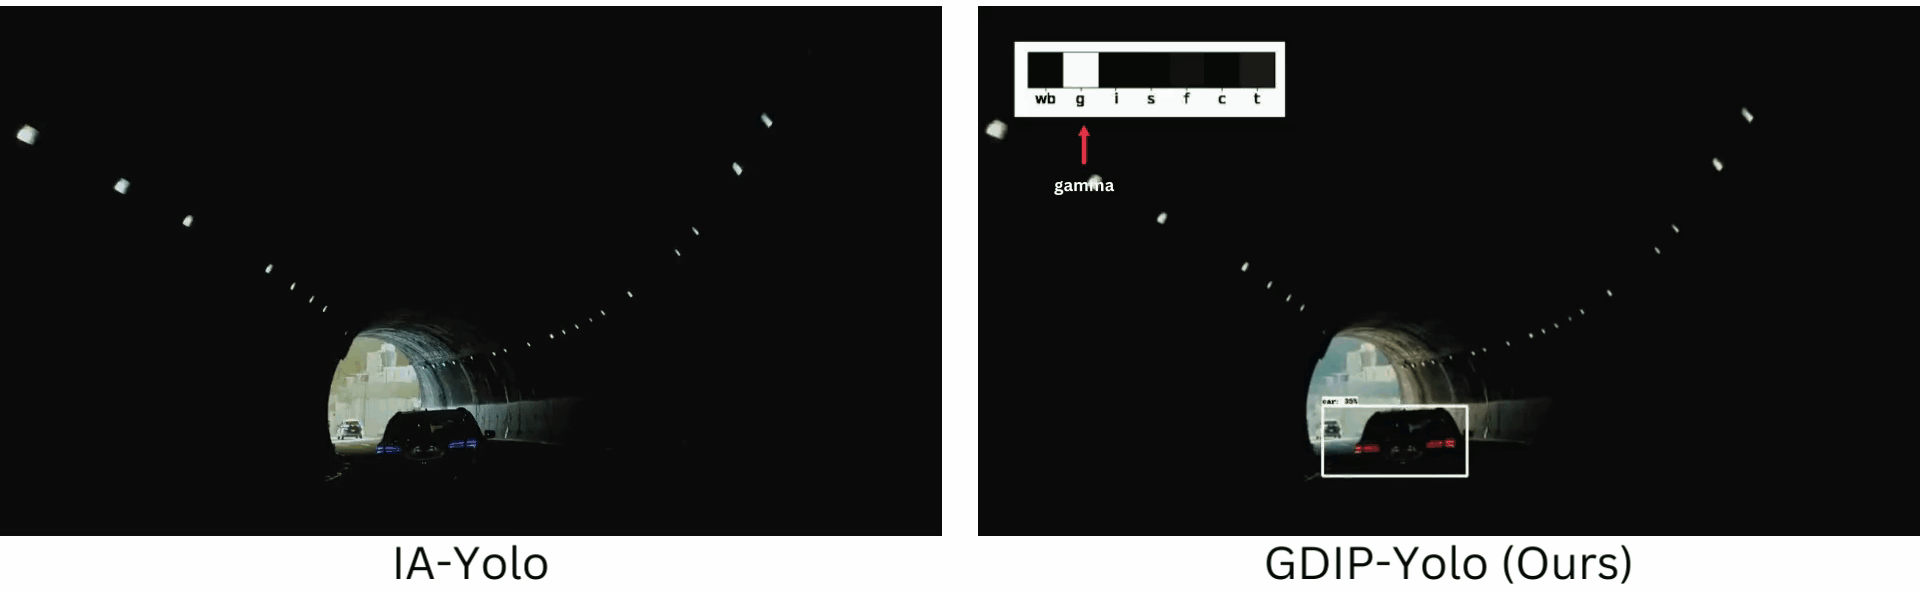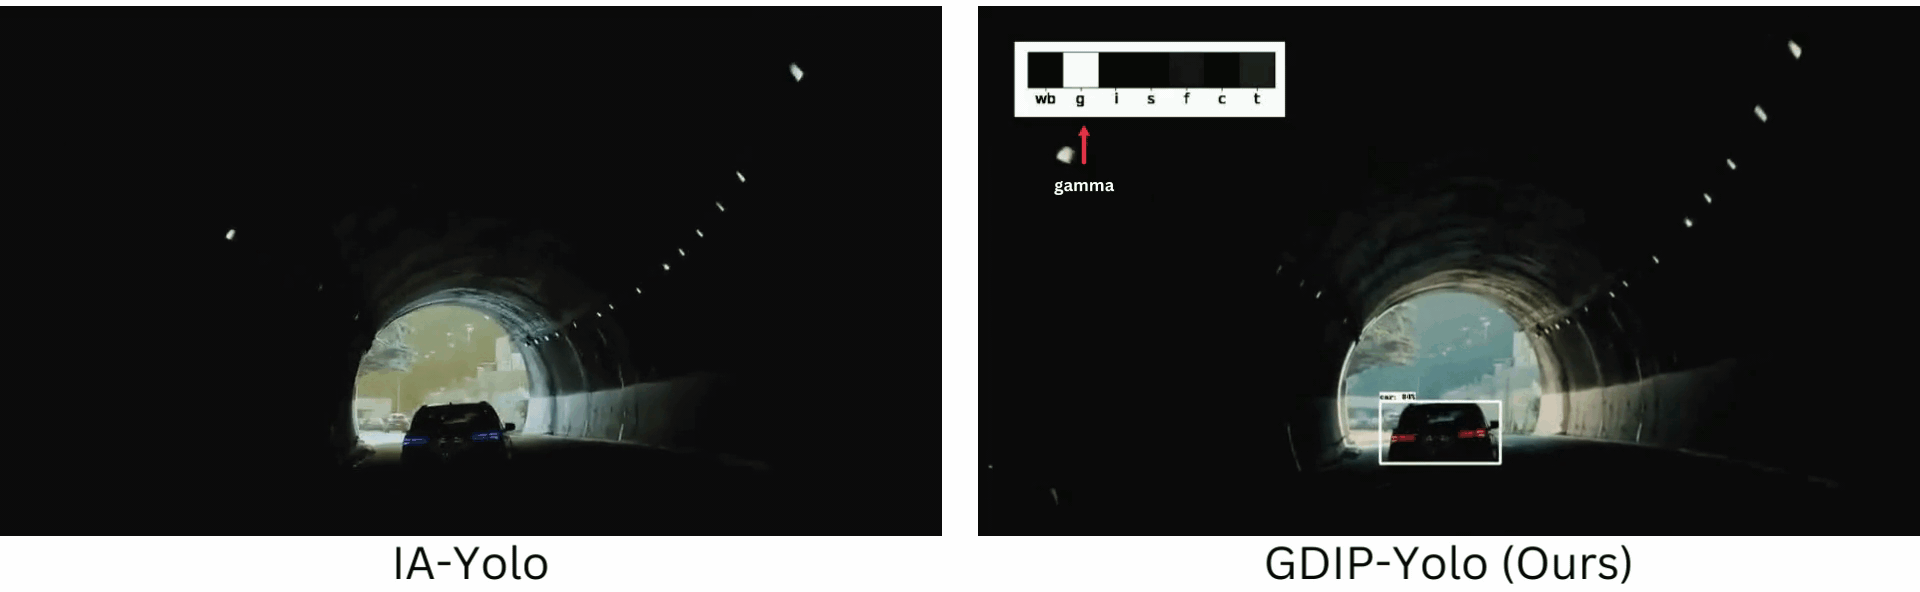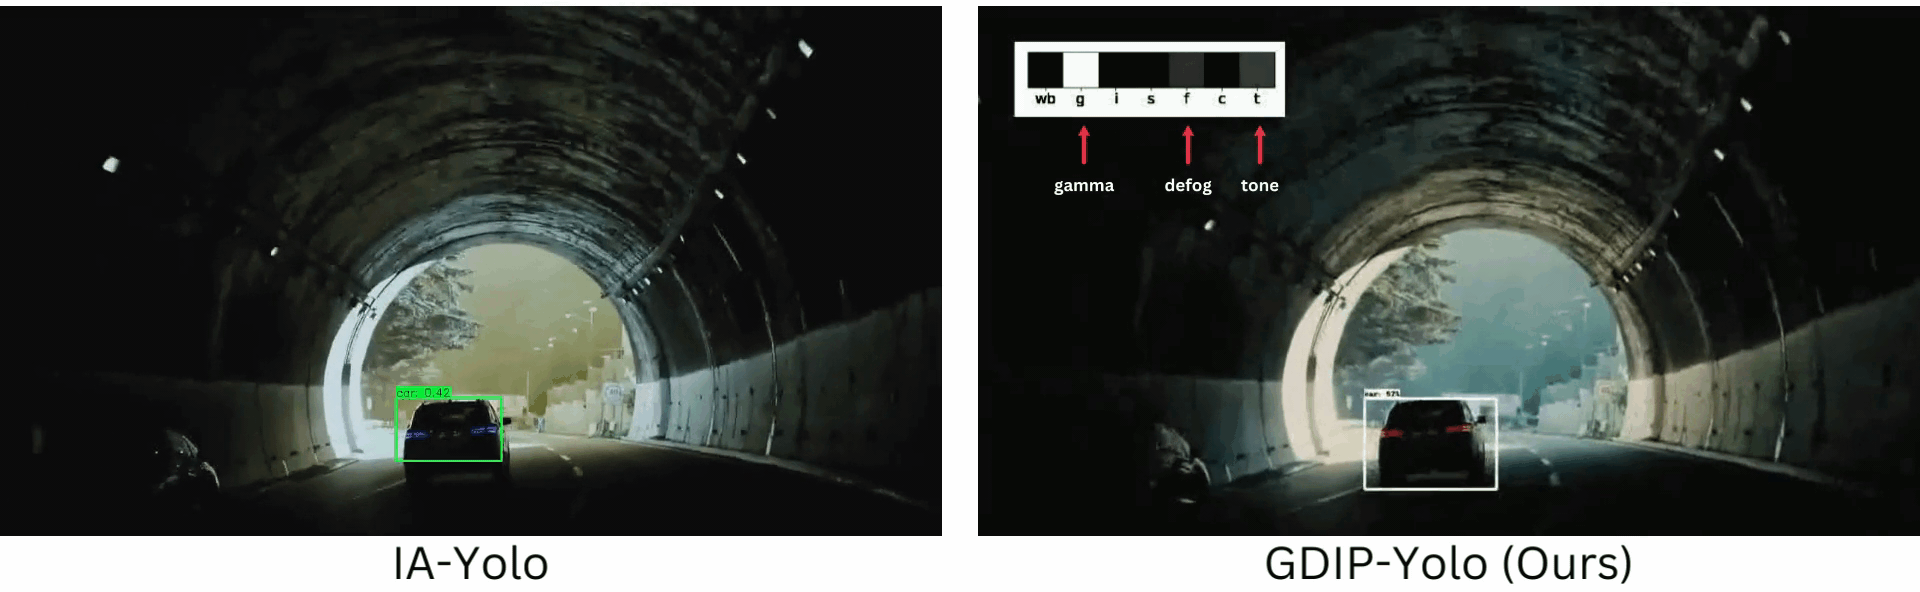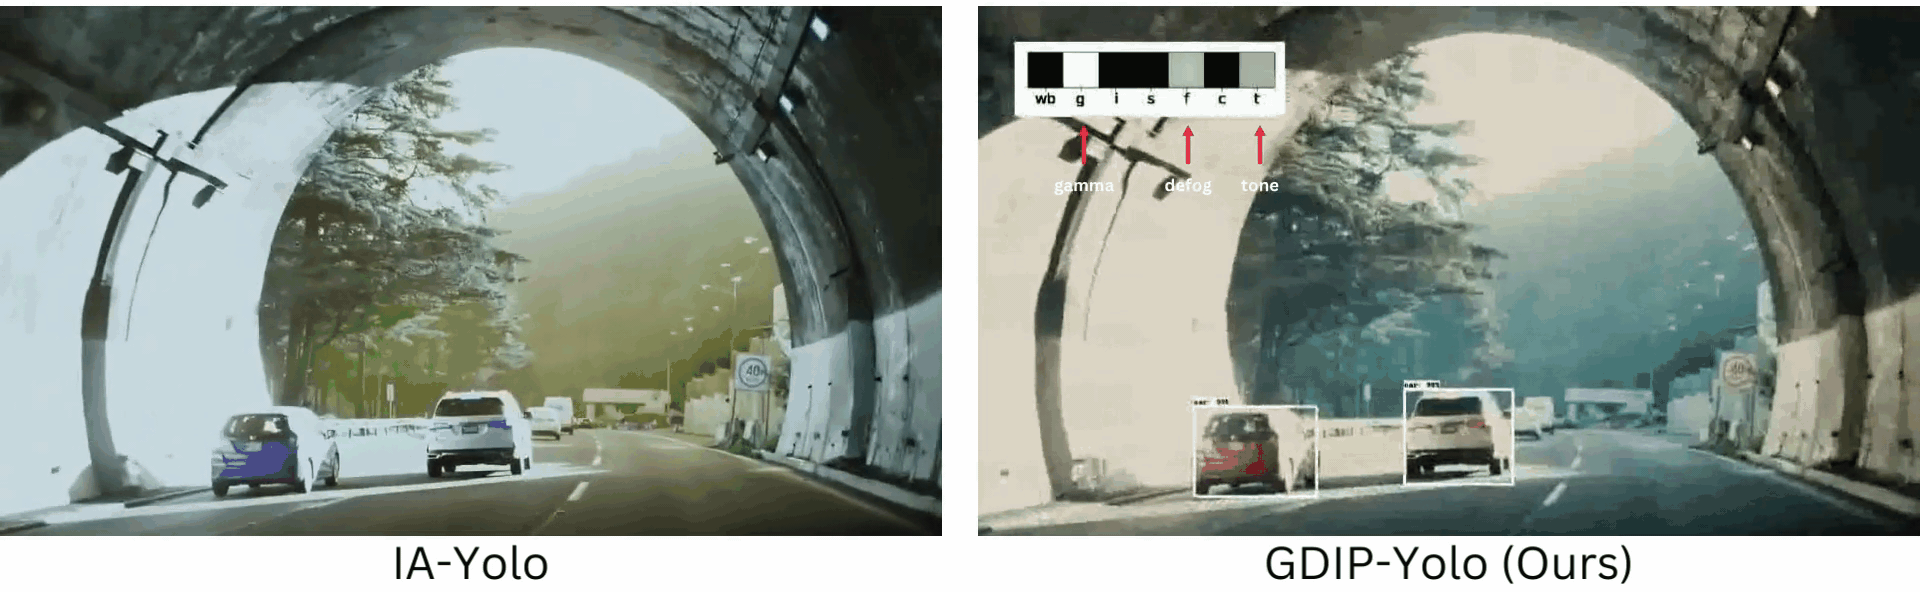
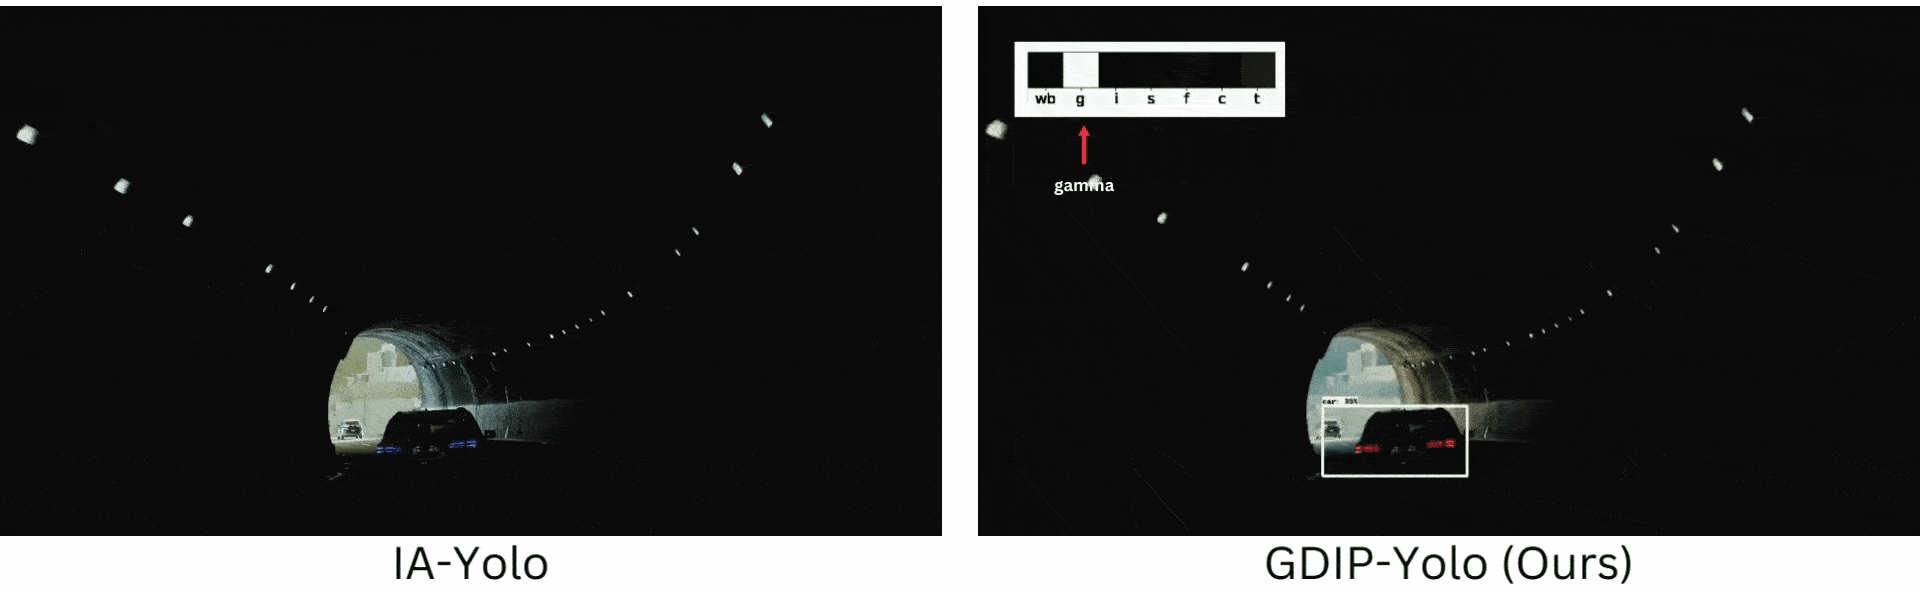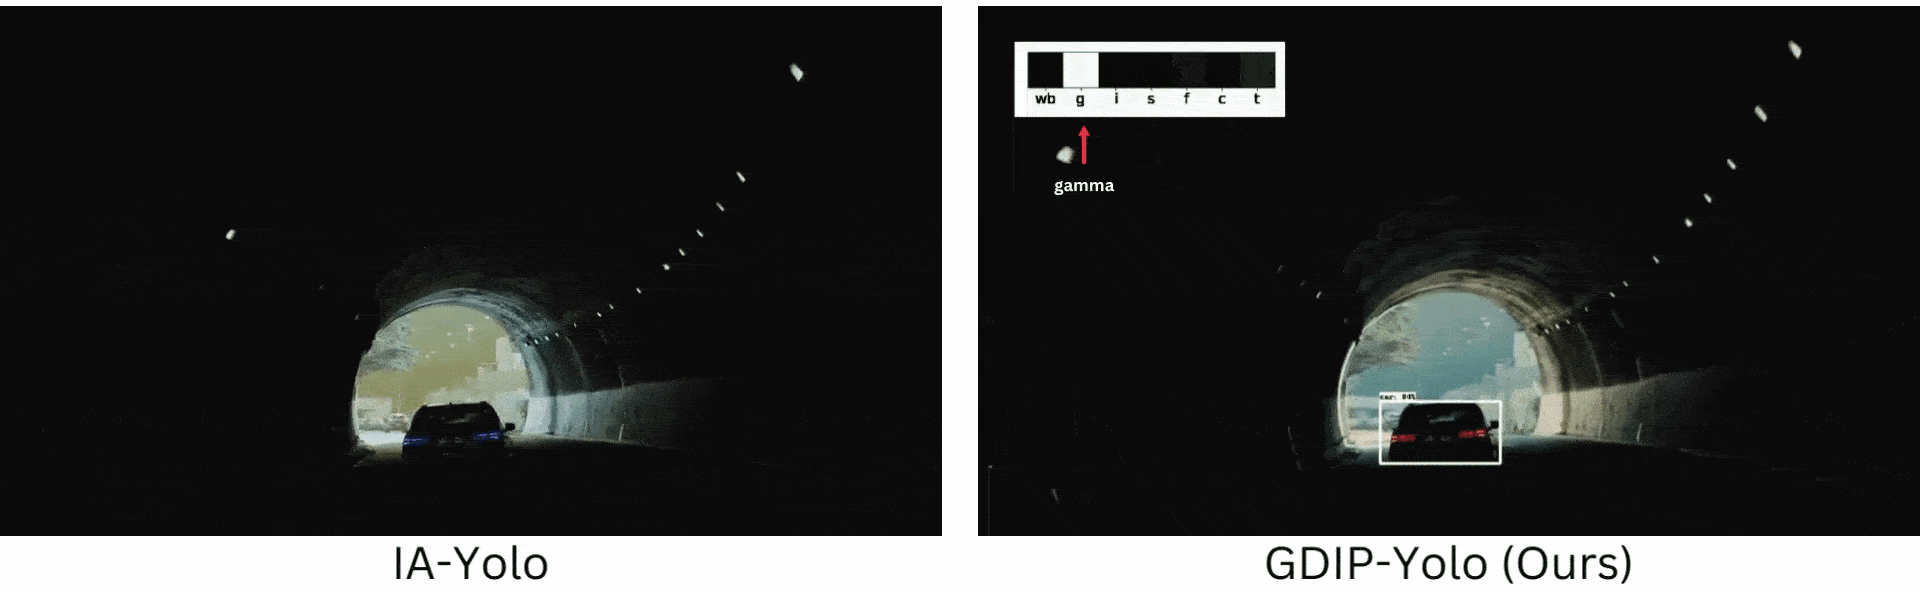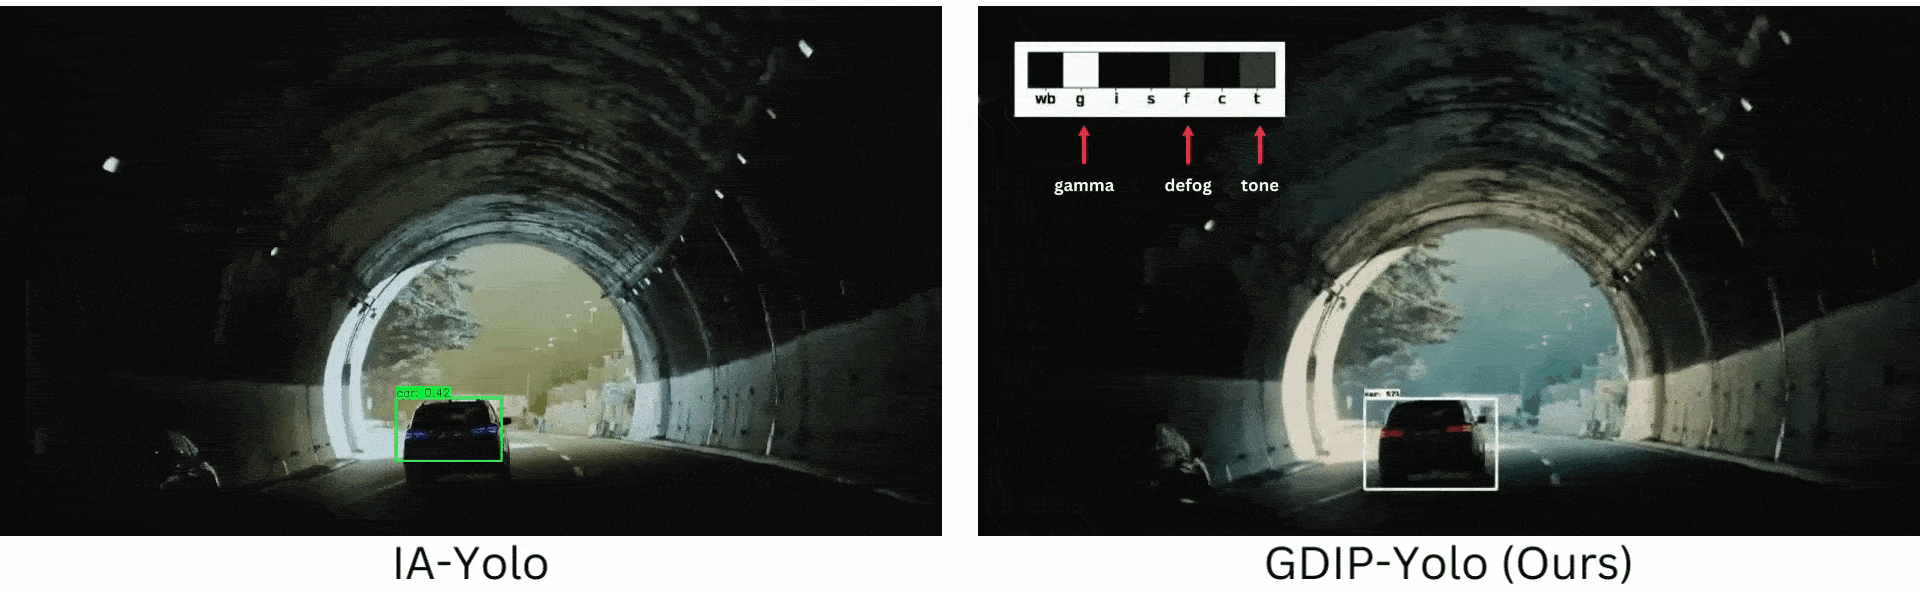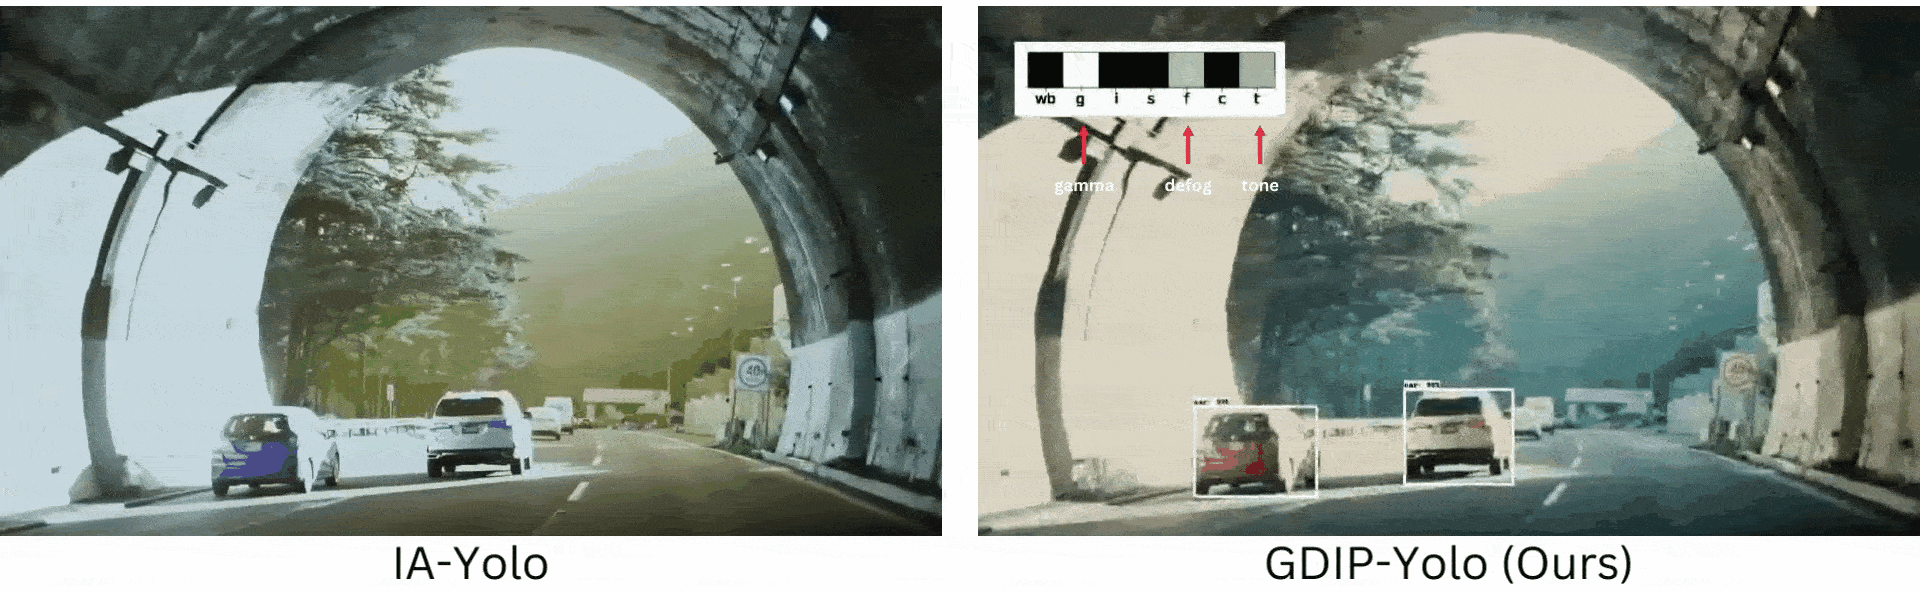
  • Proposed GDIP: Gated Differentiable Image Processing which establishes a new SOTA for object detection in foggy and low-lighting conditions.
  • Researched downstream problems like video object detection/tracking and explored Probabilistic Graphical Models (PGMs) for weather-agnostic feature refinement.


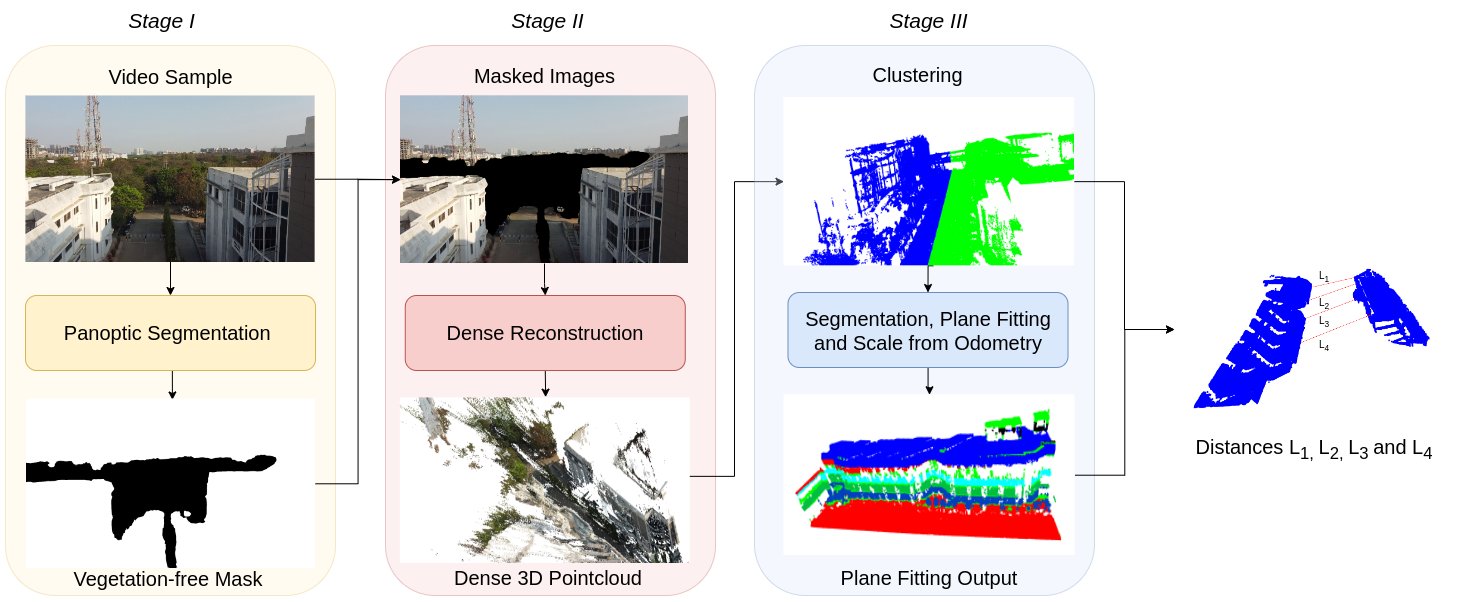
UAV-based Visual Remote Sensing for Automated Building Inspection (UVRSABI)
Advisors: Prof. Madhava Krishna, Dr. Ravi Kiran, and Dr. Harikumar Kandath

  • Automated assessment of civil structures with the help of visual remote sensing.
  • Utilized Structure-from-Motion, state estimation, odometry, etc., in conjunction with classical Computer Vision and Deep Learning-based visual inspection algorithms to robustly estimate critical structural parameters.
  • Developed and released an open-source library (UVRSABI) for the community. More details here.
Keywords: Robotics, Computer Vision, Deep Learning, Reinforcement Learning, 3D Reconstruction, Autonomous Driving, ADAS, UAVs


AMDOCS Logo

Software Engineer

AMDOCS

Aug 2020 – June 2021 Pune
Scrum Master/Team Lead: Shreyas Kulkarni
  • Responsible for B2B production-level full-stack software development.
  • Developed cross-functional telecom software solutions for Comcast's Orion project (USA).
  • Technical Stack: Java, ReactJS, SQL, Spring Boot, Maven, and Jenkins.
Keywords: Java, SQL, ReactJS, Object-oriented Programming, Microservices, Jenkins, Maven, Spring


Swaayatt Robots Logo

Research Intern

Swaayatt Robots

April 2020 – July 2020
Advisor: Sanjeev Sharma (Founder & CEO - Swaayatt Robots)
  • Improved Visual Odometry and SLAM pipelines for Level-5 Autonomy.
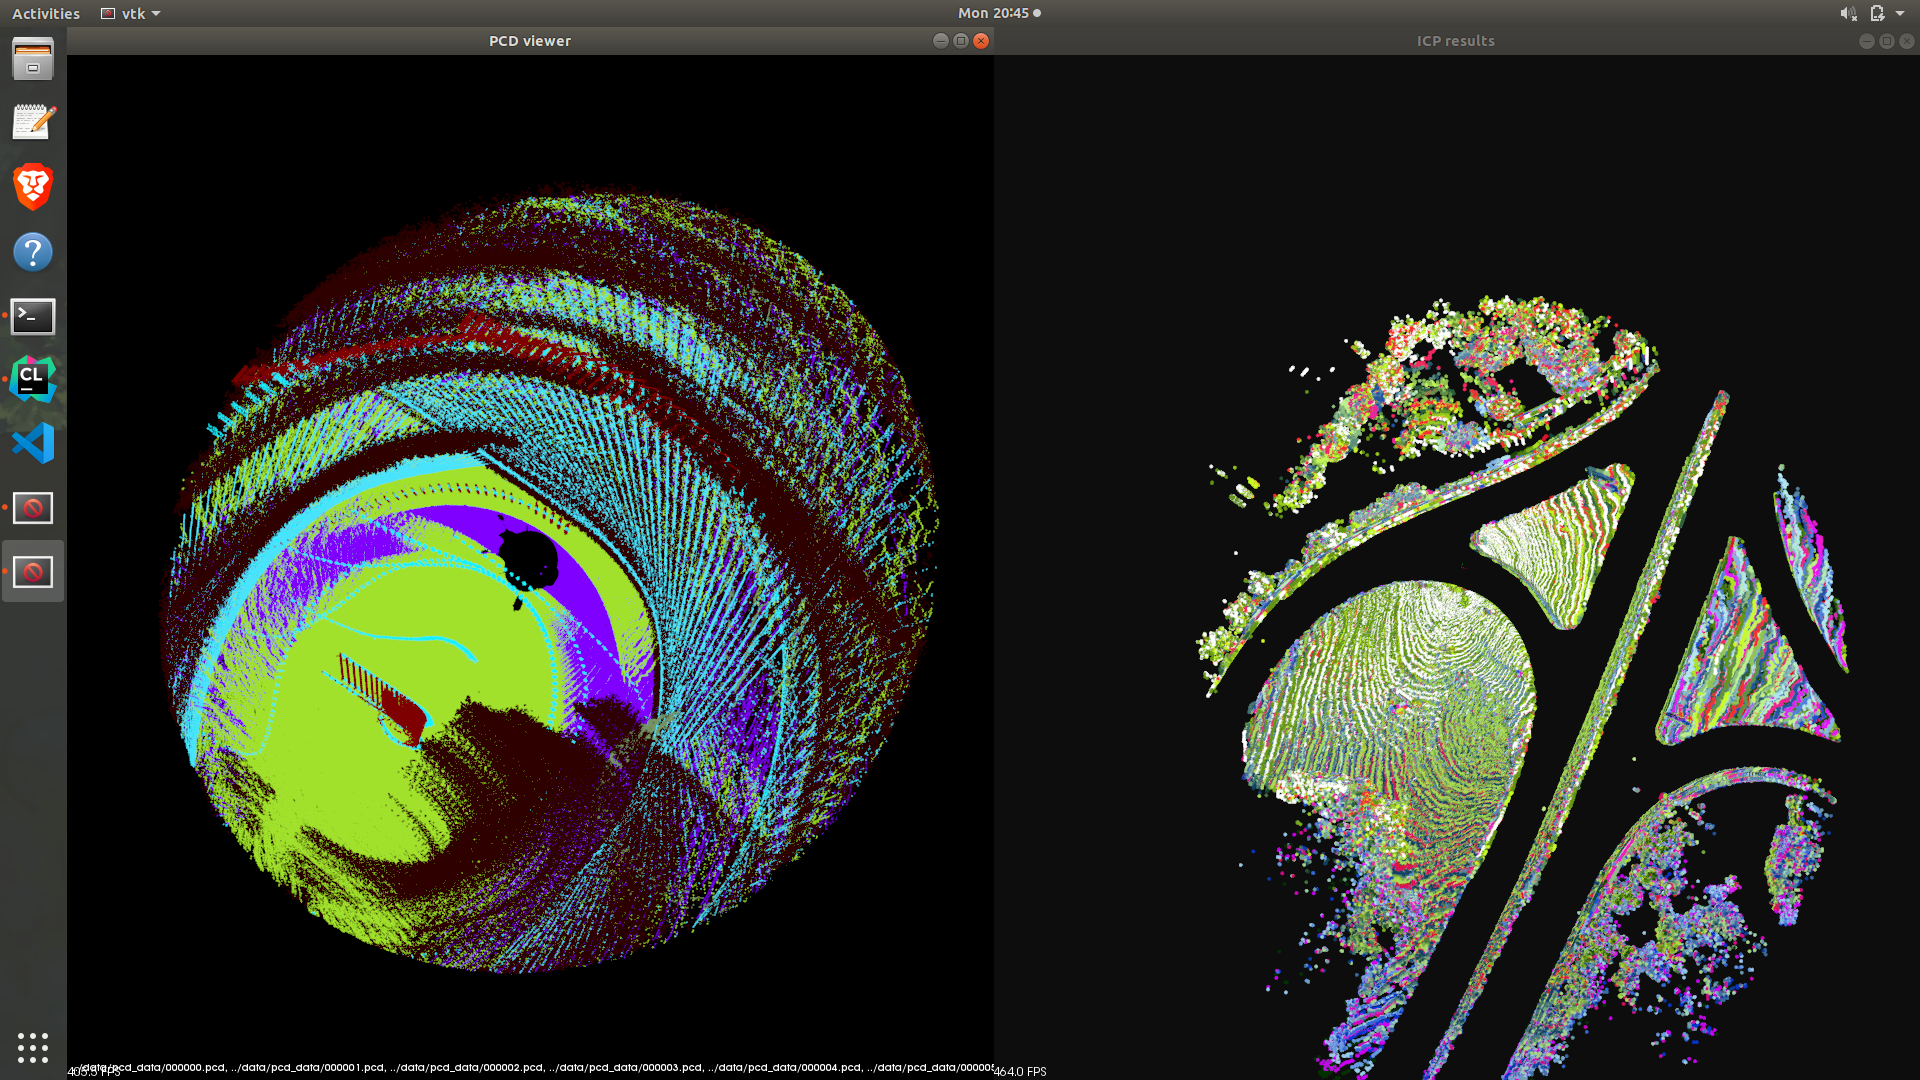
  • Devised a semantic variant of the Iterative Closest Point (ICP) algorithm, outperforming vanilla ICP in terms of matching loss and convergence time on the Semantic KITTI dataset.
  • Developed a low-level C++ library.
Keywords: Robotics, Mathematical Optimization, SLAM, ICP, LiDARs


SVNIT Surat Logo

Deep Learning Intern

Sardar Vallabhbhai National Institute Of Technology, Surat

May 2019 - July 2019
Advisor: Dr. Kishor Upla (Assistant Professor, ECED)
  • Implemented the state-of-the-art FaceNet paper and validated it on a custom dataset of 25 students.
Keywords: Face Recognition, Deep Learning

Projects

.js-id-Self

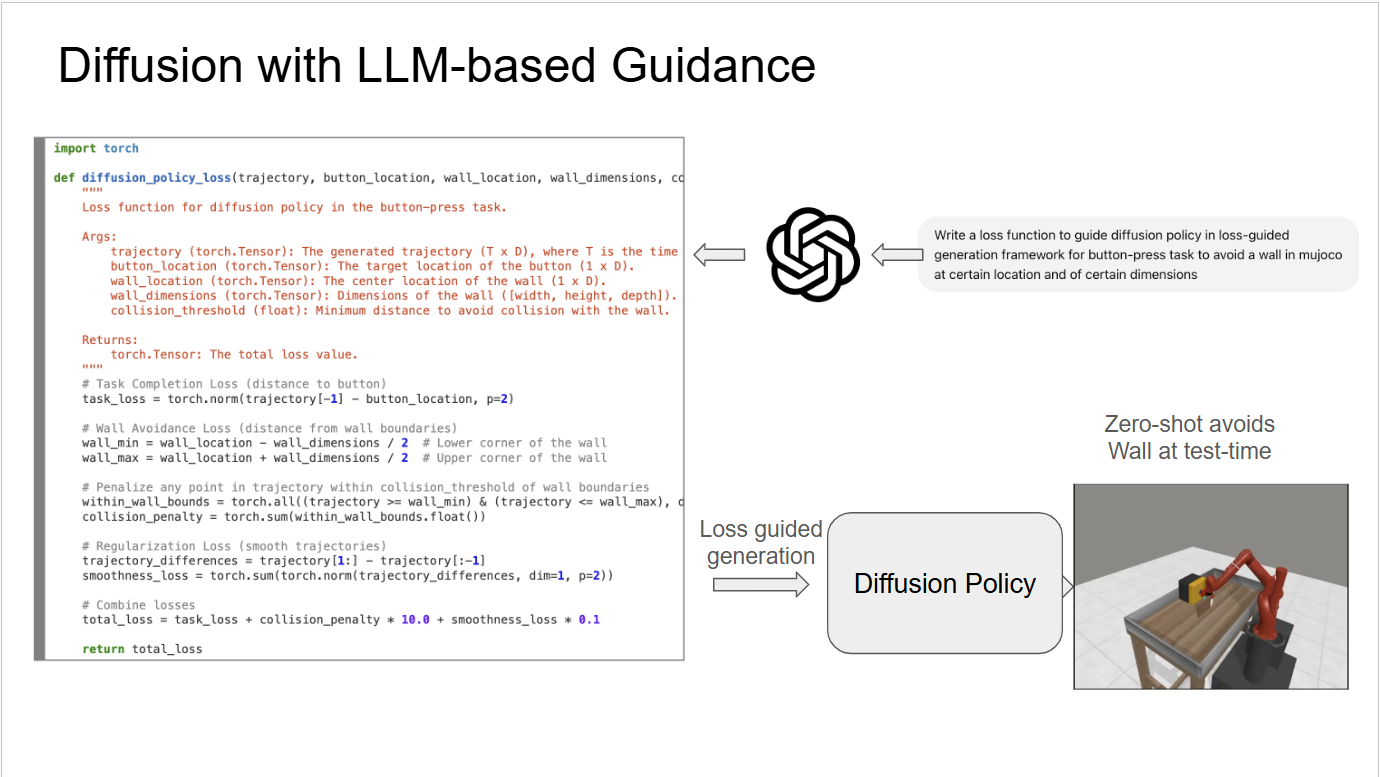
Zero-shot policy adaptation: Diffusion Models + LLMs

Zero-shot adaptation leveraging inference-time flexibility (diffusion models) and expressivity (LLMs)

EgoMimic: Scaling Imitation Learning via Egocentric Video

End-to-end robot learning for generalizable bimanual robot manipulation from embodied human data

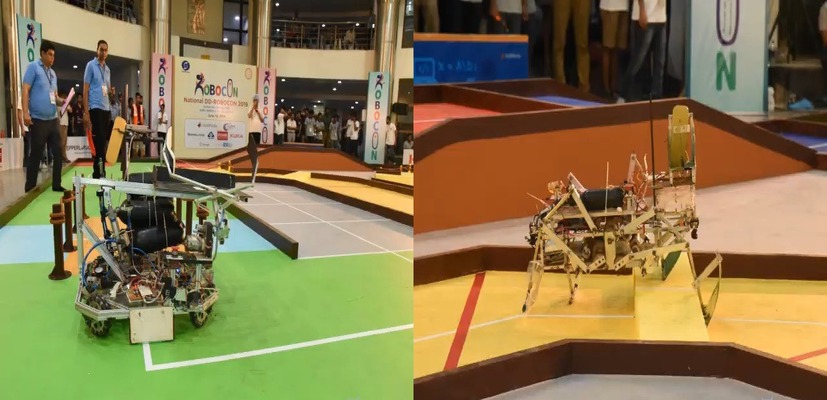
Asia-Pacific Robotics Contest 2018 & 2019

Autonomous Navigation for OmniDrive and Quadruped robots

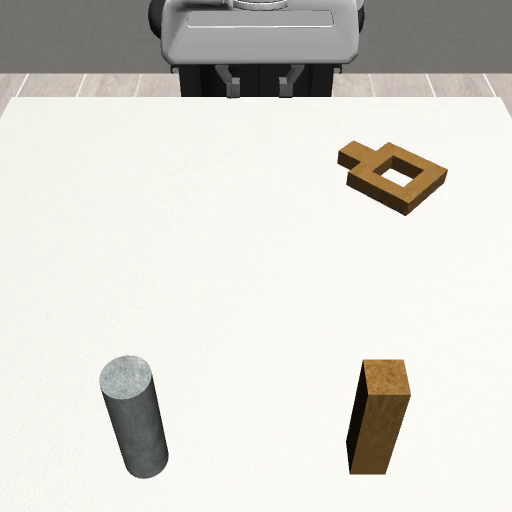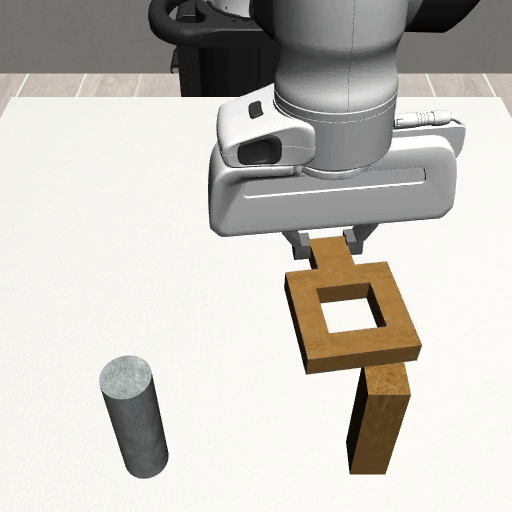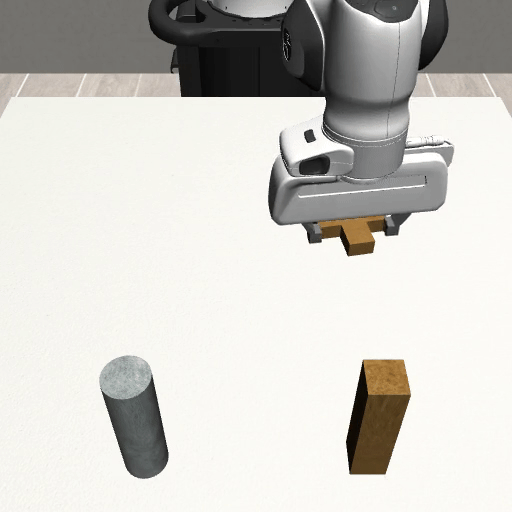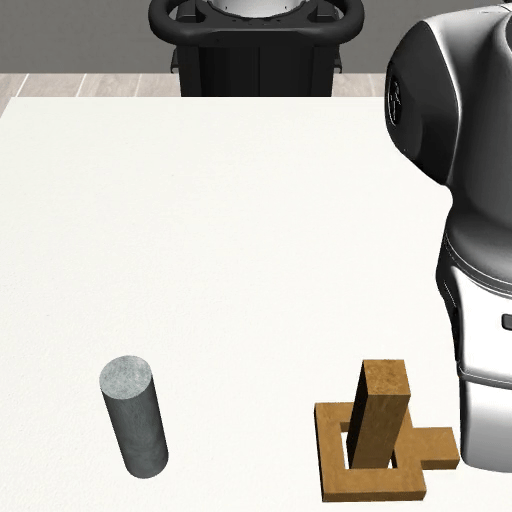
Behavior Cloning and Dynamics Models for Robot Manipulation

MLP, RNN, Diffusion policy variants and learning dynamics models in Robomimic

Vision-Language Models for Dense Feedback Reward

VLMs for Natural Language Human Feedback

UAV-based Assessment of Civil Structures

Automated building inspection using the aerial images captured using UAV.

Obstacle Avoidance for UAV

Predicting an obstacle-free patch for high level control commands

Fytbuddy: A real-time gym fitness trainer

A web app-based e-trainer using a flask web server and a Deep Learning-based model for posture correction

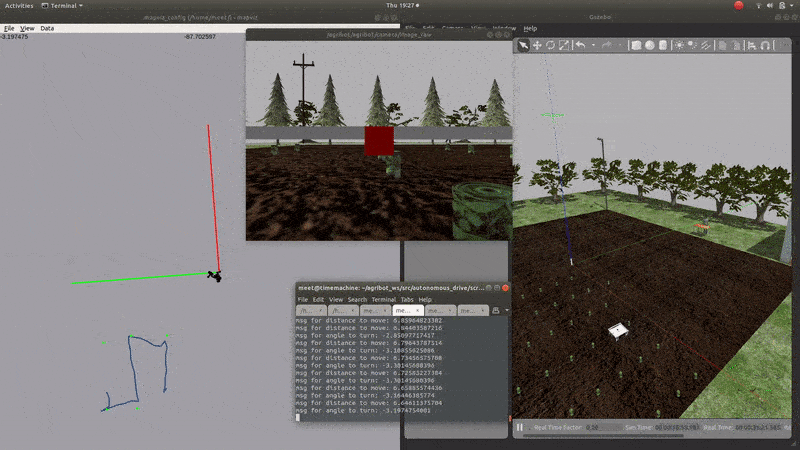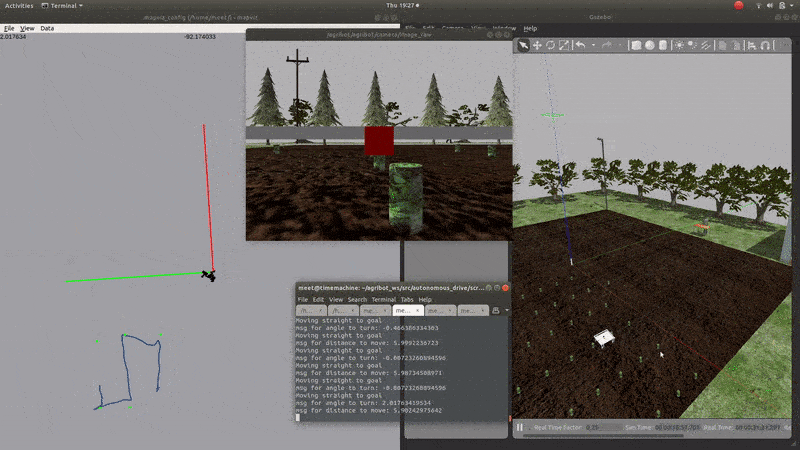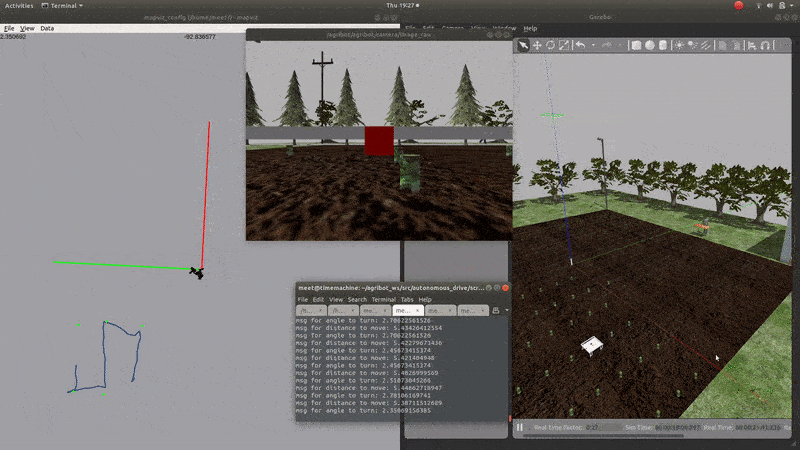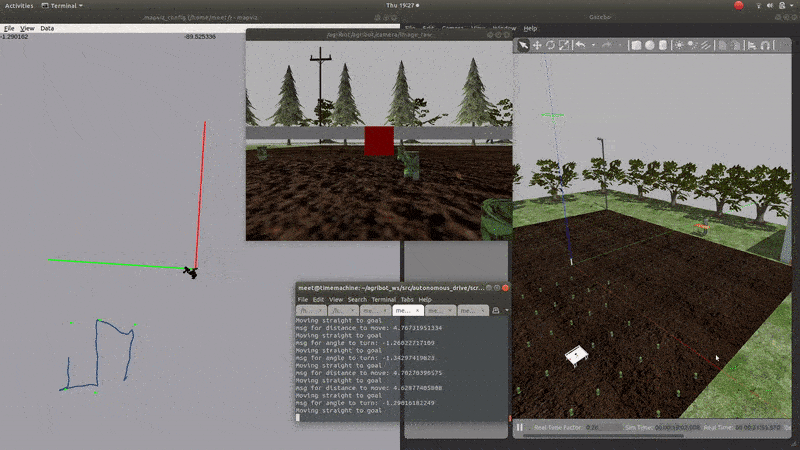
Autonomous Agricultural Robot

AGRIBOT to solve crop weed classification problem

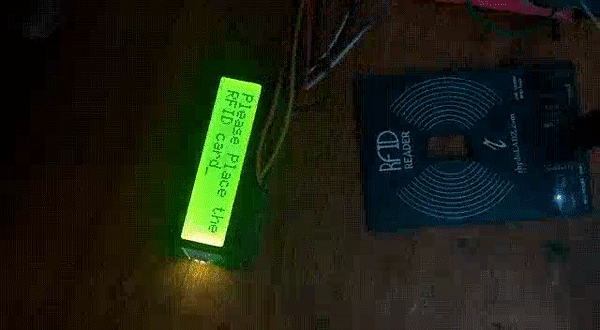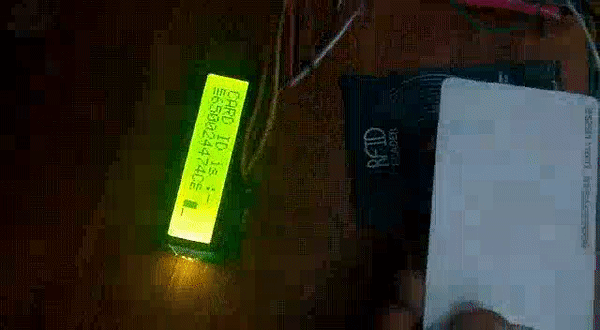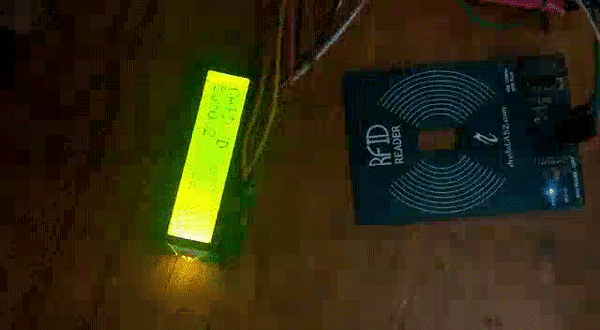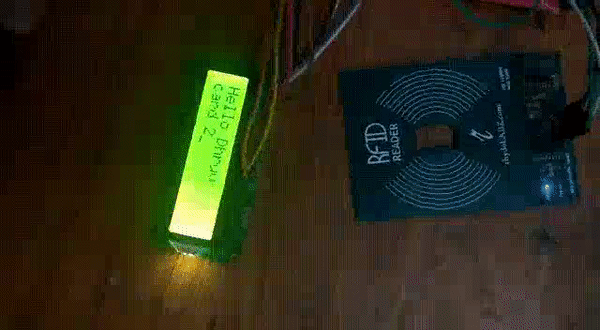
RFID System

Identification system using RFID reader, LCD display and Atmel AVR microcontroller.

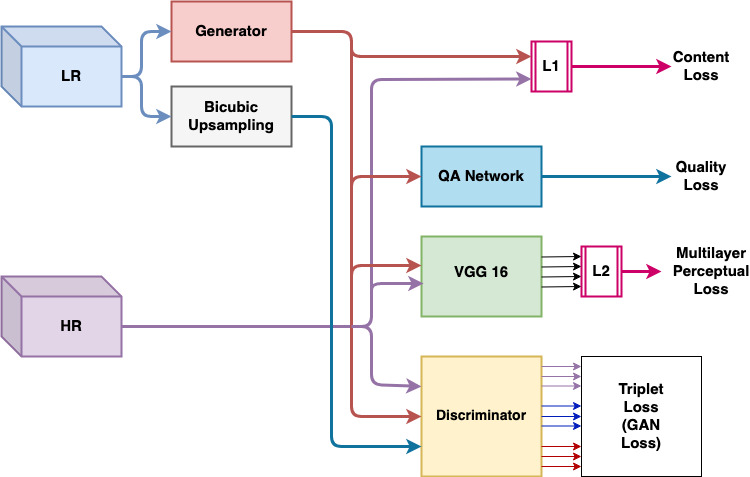
Image Super-Resolution

A triplet loss-based optimization framework for Image Super-Resolution

Mapping for level-5 Autonomy

Improved point cloud registration and mapping using semantic ICP

Object Detection in Adverse weather setting

Gated Differentiable Image Processing (GDIP), a domain-agnostic architecture for object detection in adverse conditions.

Implementation of Path Searching/Tracking algorithms

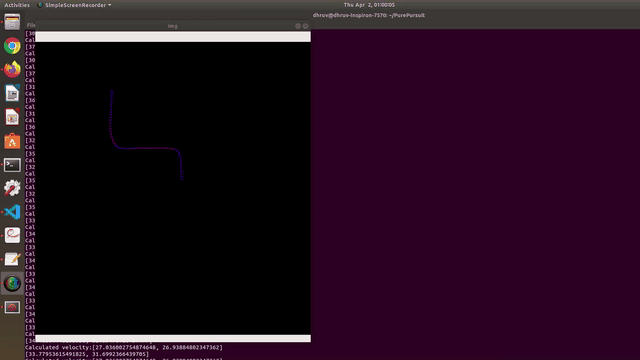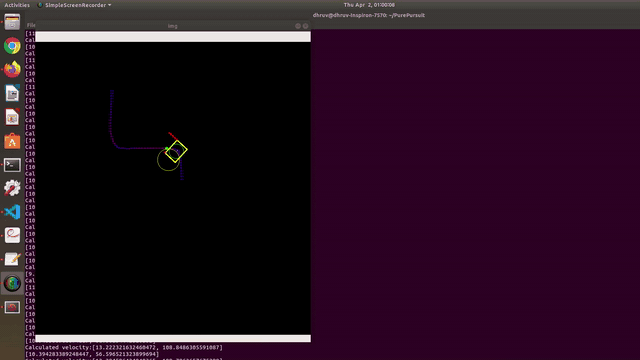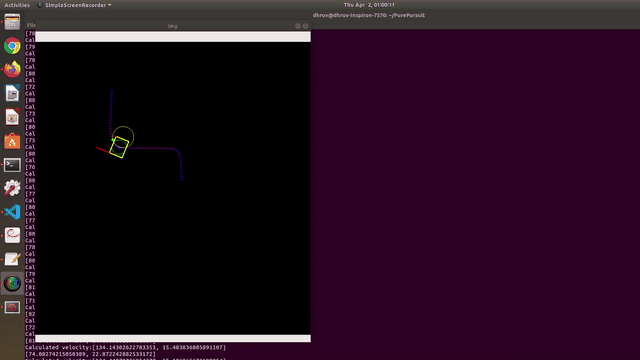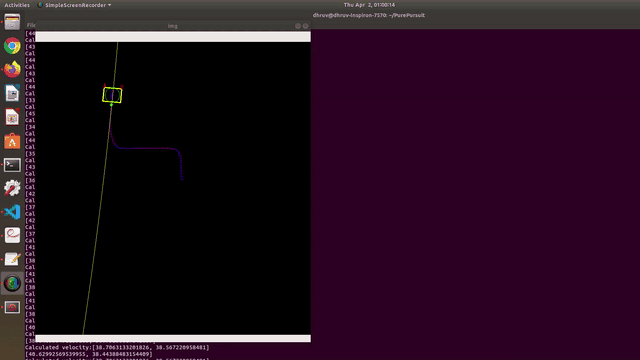
Implemented path search/track algorithms like Pure Pursuit, Djikstra, A-star etc.

Teaching

Graduate Teaching Assistant
  • Georgia Tech CS 3630: Intro to Perception and Robotics (undergrad-level) (Spring 2025)
  • Georgia Tech CS 6476: Computer Vision (grad-level) (Fall 2024)
  • Georgia Tech CS 6476: Computer Vision (undergrad-level), Georgia Tech (Spring 2024)
  • Georgia Tech CS 6476: Computer Vision (grad-level), Georgia Tech (Fall 2023)
  • Featured

    • UAV-based Visual Remote Sensing for Automated Building Inspection (UVRSABI)
      • Spotlight paper presentation at the CVCIE Workshop at ECCV 2022
      • Inaugurated by Central Road Research Institute to deploy in Telangana, India (Sept 2022)
    • AGRIBOT got funded under TEQIP-III program by Govt. of India, and we also presented at the open-source ROS Agriculture community meet. [YouTube]
    • Secured 12th and 13th rank in Asia-Pacific Robot Contest - RoboCon 2018 and 2019 respectively, among 100-plus universities. [RoboCon2019 YouTube] [RoboCon2018 YouTube]
    • Best Working Model - Stirling Engine at the National Science Day Celebrations, Physical Research Laboratory (PRL), India, during 12th grade.